Mud Head CarFTC TEAM 26910
Engineering · FTC 26910

Inside the build

See our hardware, shooter code and tuning tools.

2026–27 · Prototype v1

We’re building our first prototype. Photos are from 2025–26; code is on Benjamin-Dev. CAD, design rationale, measured test results and a new prototype demo aren’t posted yet.

01 / Mechanical design

2025–26 robot
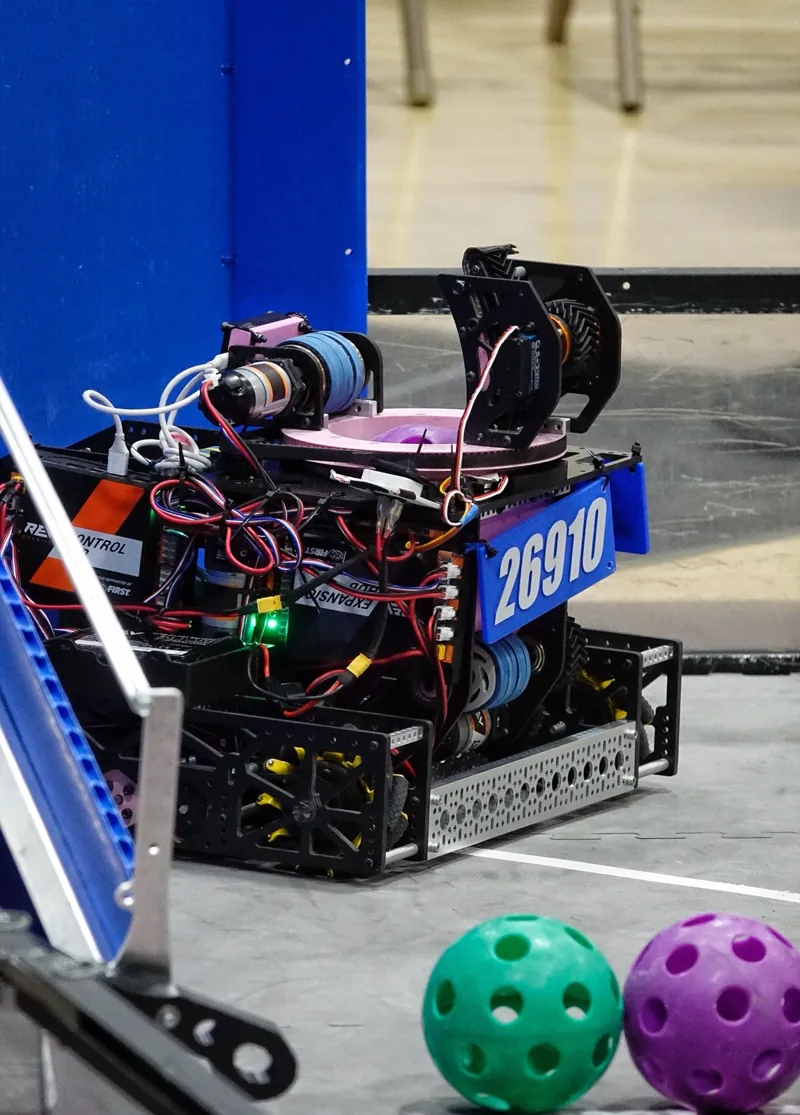
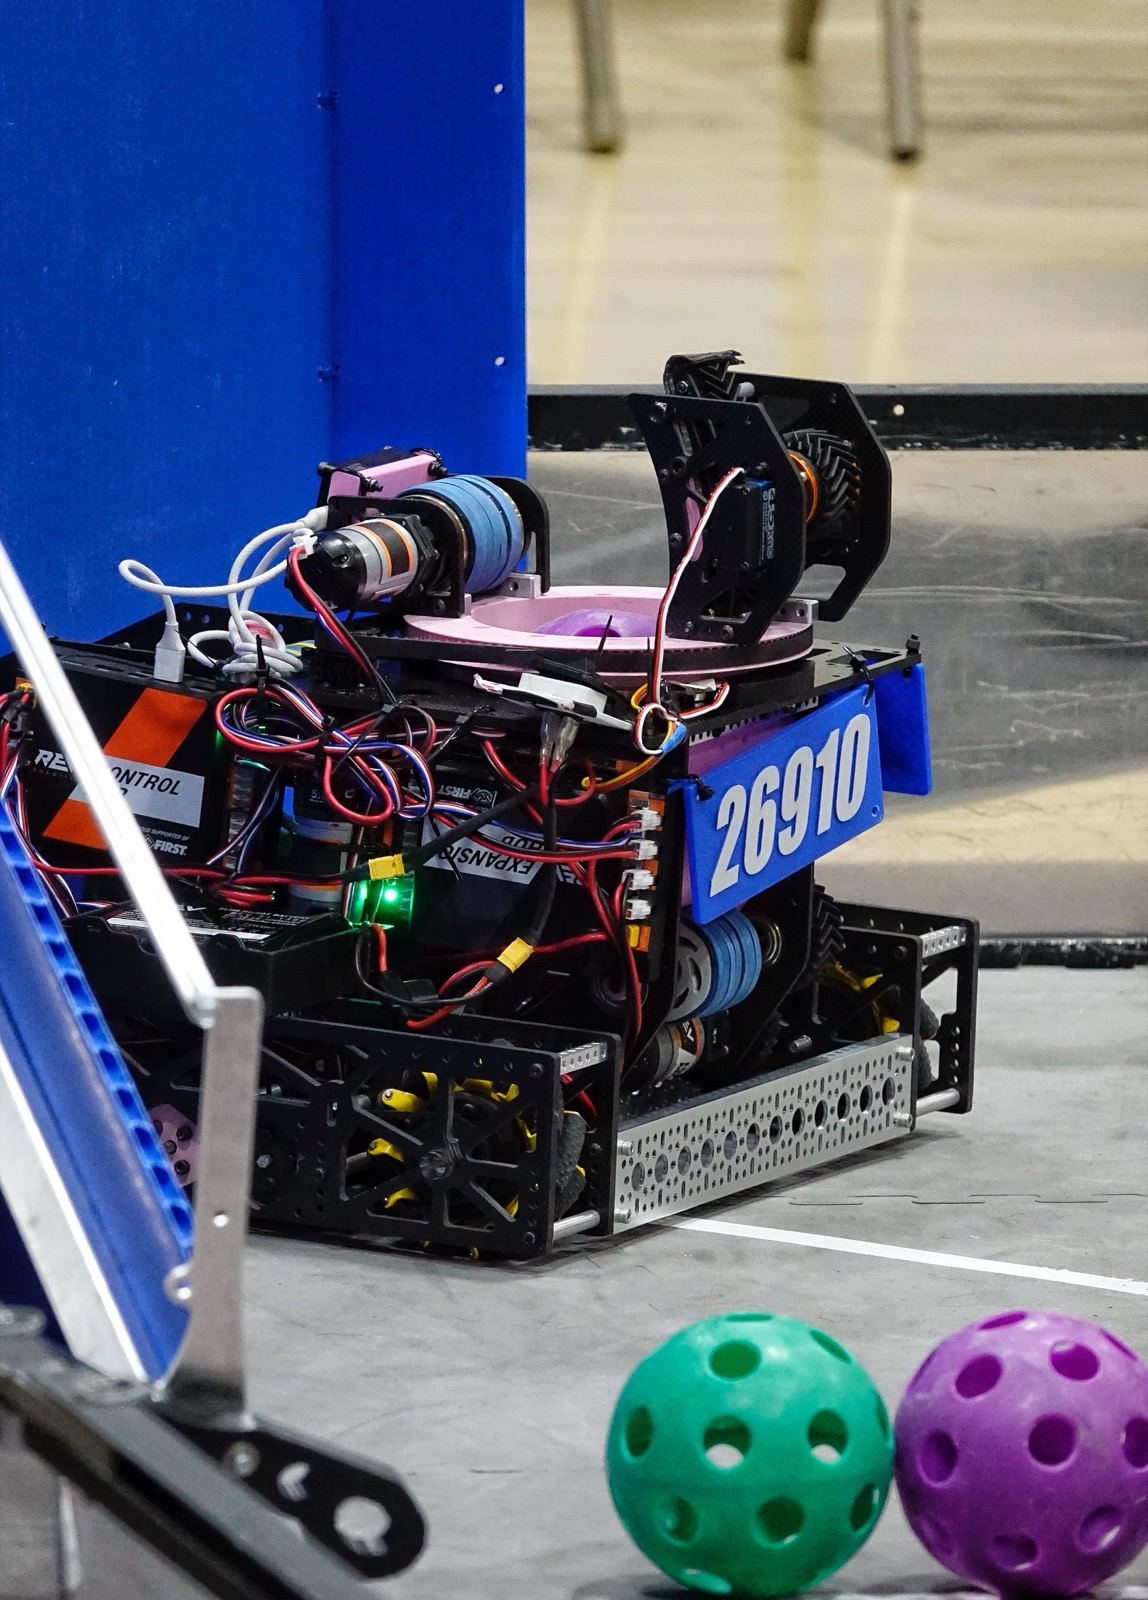
Detailed view of robot 26910 chassis, motors, wiring and pink components
Chassis, mechanisms and wiring in our 2025–26 robot.
01 Challenge
Fit the mechanisms, motors and electronics into one robot.
02 Build
The photo shows the layout and pink fabricated parts.
03 Available now
Competition photos show the assembled robot.
04 Next
Add CAD, a design tradeoff and a before-and-after mechanism test.
02 / Shooting from different distances

Java source · Benjamin-Dev
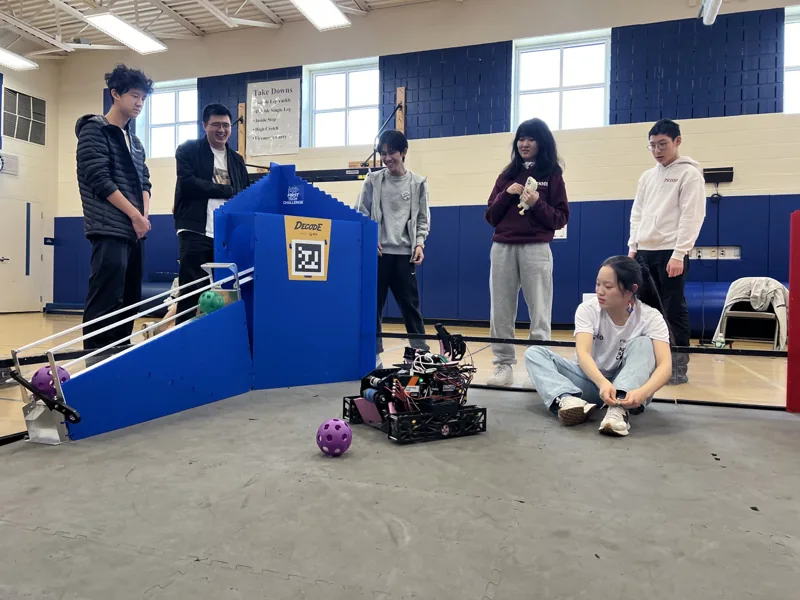
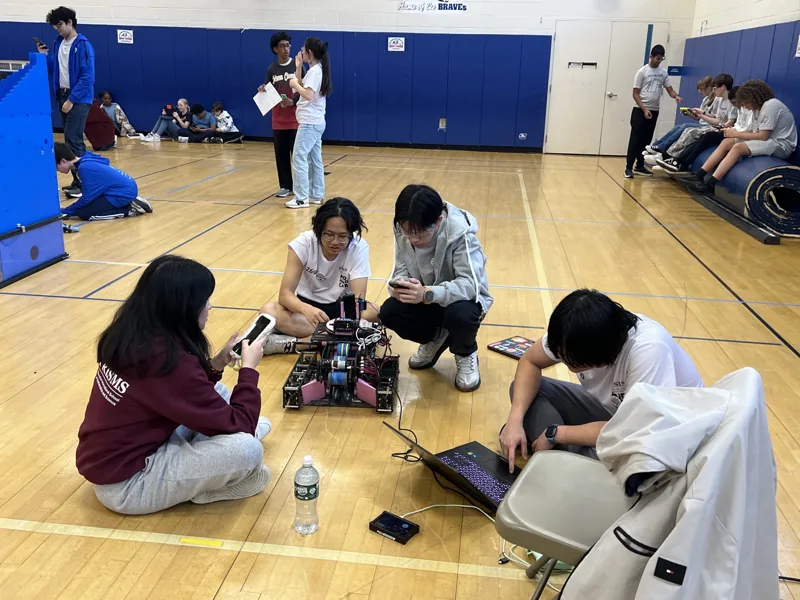
Students using a laptop beside their robot
A team work session from our photo archive.
Shooter.java · Code excerpt
double distance = displacement.getMagnitude();
ShotProfile shotProfile = calculateShotProfile(distance);
Read Shooter.java
01 Challenge
Set the turret angle, hood position and flywheel speed as the robot moves relative to the goal.
02 Approach
Shooter.java calculates the distance and direction from the turret to the goal. It selects a short- or long-range profile, then interpolates hood position and RPM between set distances.
03 Available now
The code and tuning values are public.
04 Next
Add a field demo and shot logs by distance.
View profile constants View flywheel control

Source: 984a50b · reviewed October 8, 2026

03 / Tuning the shooter

Test program
Robot 26910 at the field with team members behind it
Robot and drive team · 2025–26
ShooterTestingTeleOp.java · Code excerpt
telemetry.addData("Flywheel RPM", robot.shooter.getFlywheelRPM());
telemetry.addData("Target RPM", robot.shooter.getShooterConfig().flywheelRPM);
Read the tuning program
01 Challenge
Check whether the flywheel reaches its target speed while adjusting the turret and hood.
02 Approach
A test TeleOp lets us adjust RPM, turret angle and hood position. Telemetry and FTC Dashboard show actual and target RPM, each motor’s speed and robot position.
03 Available now
The test program is public.
04 Next
Plot actual and target RPM, then repeat a shot test before and after tuning. Record the conditions.